BlenDAgger: Blended Shared Control for Interactive Imitation Learning
Research Project, in Submission as First Author
Paper | Code | Website (coming soon)
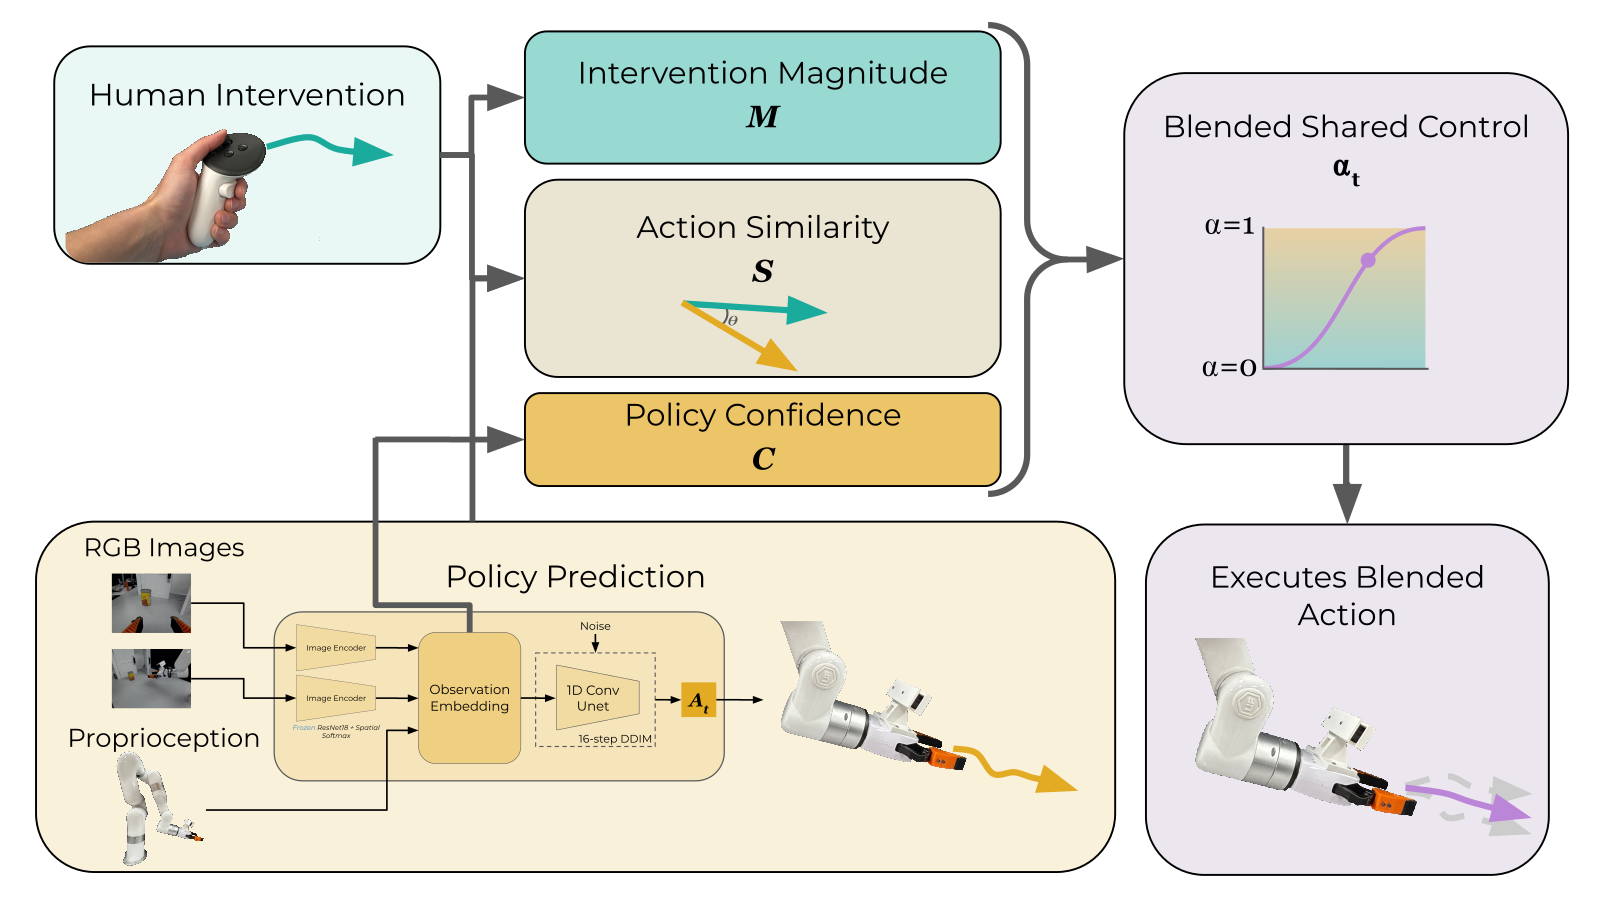
Novel approach for collecting data to fine-tune imitation learning policies using blended shared control during interventions for better autonomous performance. In comparison to full human control during interventions (HG-DAgger), our approach results in:
- Higher autonomous performance by 30 or more percentage points on two long horizon real-world tasks
- ~14% faster data collection for novice demonstrators, measured with a user study
- 57% smoother transitions between autonomous rollouts and human interventions